
Drive coil ampere turns for seconds pendulum

Drive coil ampere turns for seconds pendulum

Home › Forums › Clocks and Scientific Instruments › Drive coil ampere turns for seconds pendulum

Viewing 25 posts - 1 through 25 (of 41 total)
  • Author
    Posts
  • #864630
    carlw
    Participant
      @carlw

      I have started a pendulum clock based upon John Wildings’ version of the ME Jubilee Clock and using my electronic Hipp drive circuit.  The seconds pendulum has a 10 lb bob and I hope to be able to fit the four optos within a 2 – 3 deg swing.  Bit of a space problem here that I hope to suss out.

      What I need is a starting point for the drive coil.  The coil core will be nylon so that I can use a NIB magnet in the end of the pendulum.  Any suggestions for ampere-turns of the coil would be most welcome.

      Carl W

      #864635
      John Haine
      Participant
        @johnhaine32865

        https://sound-au.com/clocks/free-pendulum.html

        The coil design in this might be helpful.

        #864651
        duncan webster 1
        Participant
          @duncanwebster1

          At some point you’ll have to tell us why it needs 4 optos

          #864723
          carlw
          Participant
            @carlw

            John Haine: Thanks for the link.

            Duncan: I’ll give you the real story.  I built most of John Wilding’s Large Balance Wheel Clock and found it to be quite noisy.  So, I designed and built an electronic Hipp drive circuit that is entirely quiet.  It was published in ME magazine in issues 4694 – 4696.  The circuit requires 4 opto-interrupters and there is a lot of room to accommodate them below the 5″ diameter balance wheel.  A flag mounted on the balance wheel travels through the opto apertures, decides if the balance wheel requires an impulse, times the impulse, and its duration.  A seconds pendulum swinging 2 -3 degrees may not have the equivalent length for the optos to perform the same functions if they are mounted linearly.

            I do not know much about clocks.  I had assumed that the heavy bob would need a lot more force than the balance wheel.  So, I just now did the experiment that I should have done: I pushed the pendulum and then pushed the balance wheel.  Not a lot of difference.  Now it is apparent that the real question is: will I need a much larger drive coil for the pendulum. The circuit is not required to start the pendulum from rest, only to make up lost energy.  IIRC, the balance wheel is operating on 3vDC from the 5vDC TTL power supply so I may be able to use the design that I used for the first clock. There are more ampere turns available by increasing the voltage.

            Anyway, Duncan, thanks for the ping and getting me to thinking better.

            Carl


            #864738
            John Haine
            Participant
              @johnhaine32865

              The impulse only has to provide enough energy to overcome the energy lost since the last one. This does not depend on the bob mass but more on its aerodynamic drag. Without knowing the configuration of your drive coil and magnet it’s very difficult to comment on the AT needed, but probably much less than you might think.

              You should be able to use only 2 optos, one at bottom dead centre (BDC) for the impulse,  the other at the nominal turnaround point (TAP)  to govern amplitude and tell the control which side the pendulum is. I have a clock which uses only 1 opto but has an Arduino and uses a gravity escapement.

              #864756
              duncan webster 1
              Participant
                @duncanwebster1

                Using a magnet on the end of the pendulum implies something like a fedchenko drive, so you only need one opto or hall effect to detect end of travel. I’m away from home at present, will dig out the relevant ME when I get home if I still have them.

                #864760
                carlw
                Participant
                  @carlw

                  Righto!  I began my electric clock experiments with both single and dual coil Fedchenko drives using single and dual transistor switches.  I mined the Internet for circuits.  Not knowing much about clocks, I started out doing things wrong with a light-weight bob on a seconds pendulum with flexible mounting.  The vibration was intense.  Some thought suggested that the problem was that the sudden turn-on of the impulse occurred while the pendulum magnet and the drive coil were at or near their point of maximum engagement.  It was effectively a hammer blow.  I accidentally discovered a serious problem with this type of drive.  A single opto at “bottom dead center” will have the same problem.

                  I designed a different drive circuit in which the drive coil is energized when the coil and pendulum magnet are some distance apart, and their interaction is significantly less abrupt because the force increases gradually.  The drive impulse is turned off when the lead edge of the magnet is at the center of the coil to eliminate any drag if the center of attraction goes past ‘bottom dead center.’  The electronic Hipp drive also will impulse only when the pendulum swing has decreased a pre-determined amount.  Measuring the swing and independently timing the initiation and duration of the drive impulse requires 4 optos, four set-reset flip-flops and a transistor power switch.

                  May I suggest that you visit your favorite artificial intelligence to inquire about this known problem with Fedchenko drives.

                  PS: I remember reading about a sinusoidal drive impulse.  Perhaps this idea could be applied to the Fedchenko drives to reduce the vibration.
                  Carl

                  #864894
                  John Haine
                  Participant
                    @johnhaine32865

                    I’m not quite sure what you mean by a Fedchenko drive exactly. If his drive suffered from vibration it certainly didn’t stop it being the most precise pendulum clock made in series production, being clearly able to detect tidal g variations. Fedchenko’s magnet and coil arrangement is tricky to make but gave a very clean unidirectional impulse in the direction of pendulum motion.

                    There’s a class of clocks that have an axially mounted magnet on the end of the rod swinging over a coil, which might be what you are referring to, in the fashion described in the link I gave. I’ve made a couple of these, vibration wasn’t a significant problem with either. Perhaps because only a very small impulse is needed. Generally they apply the impulse by repulsion just after BDC and usually use the voltage pulse induced in the coil to sense position, as did Fedchenko’s mk2 clock.

                    Synchronome clocks have a very hammer-like impulse and lots of resulting rod vibration but nevertheless can be very accurate.

                    In my limited experience of AI it usually gives uninformed and misconceived anwers to horological questions.

                    I know of 3 people who have made successful sinusoidal drive clocks. I don’t see how this could be applied to a Fedchenko drive, please explain.

                    #864931
                    carlw
                    Participant
                      @carlw


                      John: I do not have enough experience with AI and horology to comment any more than this: Gemini’s discussion confirmed my experience.  I will take care in using it further.

                      When I was mining Google for electronic drive circuits to replace the noisy electro-mechanical Hipp drive, the circuits which used a signal from a single or dual coil as Fedchenko type.

                      Sine drive: that was a scientific wild ass guess by me.  If the square wave signal generated by turning a transistor on and off could be modified into a sine wave, it might provide a smoother impulse.  I’ve no idea of how this might be done and whether it might be a useful idea.

                      “Generally they apply the impulse by repulsion just after BDC.”   I’ve scratched my head a bit about how that might be done and how it might be better than applying the impulse by attraction on approach. Do you have schematic for this?


                      #865176
                      John Haine
                      Participant
                        @johnhaine32865

                        “Late impulsing” is described with a couple of schematics in the sound-au link I posted. The benefit is that the induced voltage from the drive coil has a fast edge crossing zero at bdc from which to time the impulse.

                        As nearly all mechanical clocks including the most accurate apply impulses with very square waveforms I don’t really see what problem you’re trying to solve. I’ve recently worked on the Bateman clock which applies a square current pulse to an electromagnet that attracts a vane into an air gap. Pendulum sensed by an opto. Completely silent in operation.

                        Two types of sine drive. In one a short impulse is given a a raised-sine profile to avoid sharp edges. The Synchronome is reputed to do this but is nevertheless very noisy and the pendulum rod vibrates quite a lot.

                        In the other the pendulum velocity is sensed by a magnet and coil to generate a sinusoid that is applied as a force though the same or another coil. Joe Noci has been describing such a system over at https://groups.io/g/Horological-Science-Newsletter/topics . Other makers include Ned Bigelow, Bob Matthys and Andrea deMarchi.

                        #865192
                        John Haine
                        Participant
                          @johnhaine32865

                          Just to add that you may find other interesting info on the HSN site – worth signing up. There is also an associated irregular journal, Horological Science News, (I’m co-editor) with a long archive that might be interesting.

                          #865303
                          John Purdy
                          Participant
                            @johnpurdy78347

                            Carl

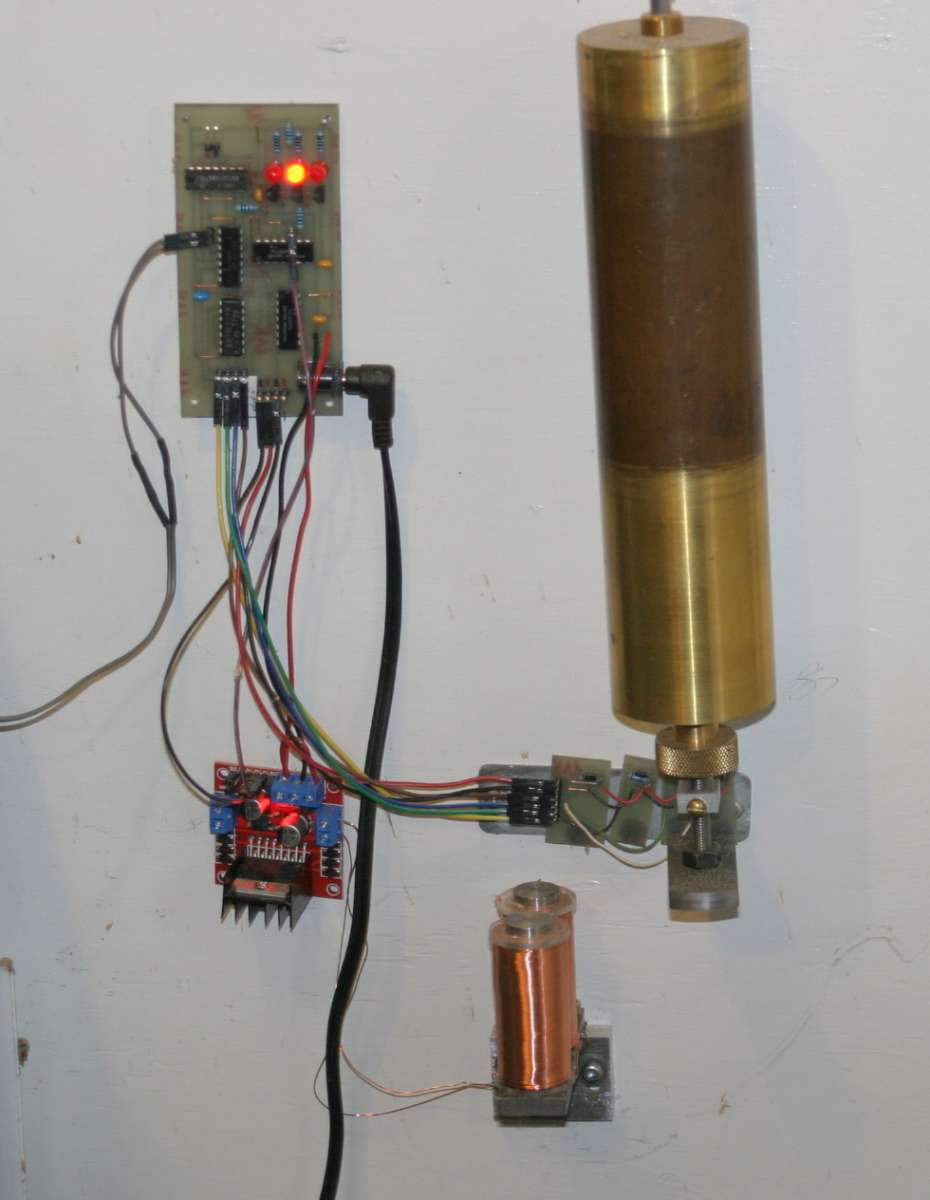
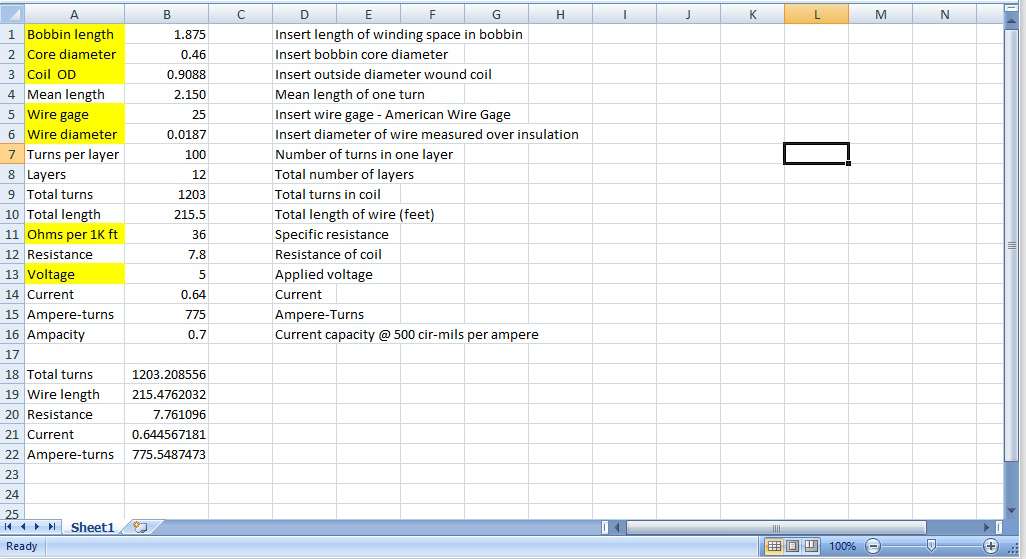
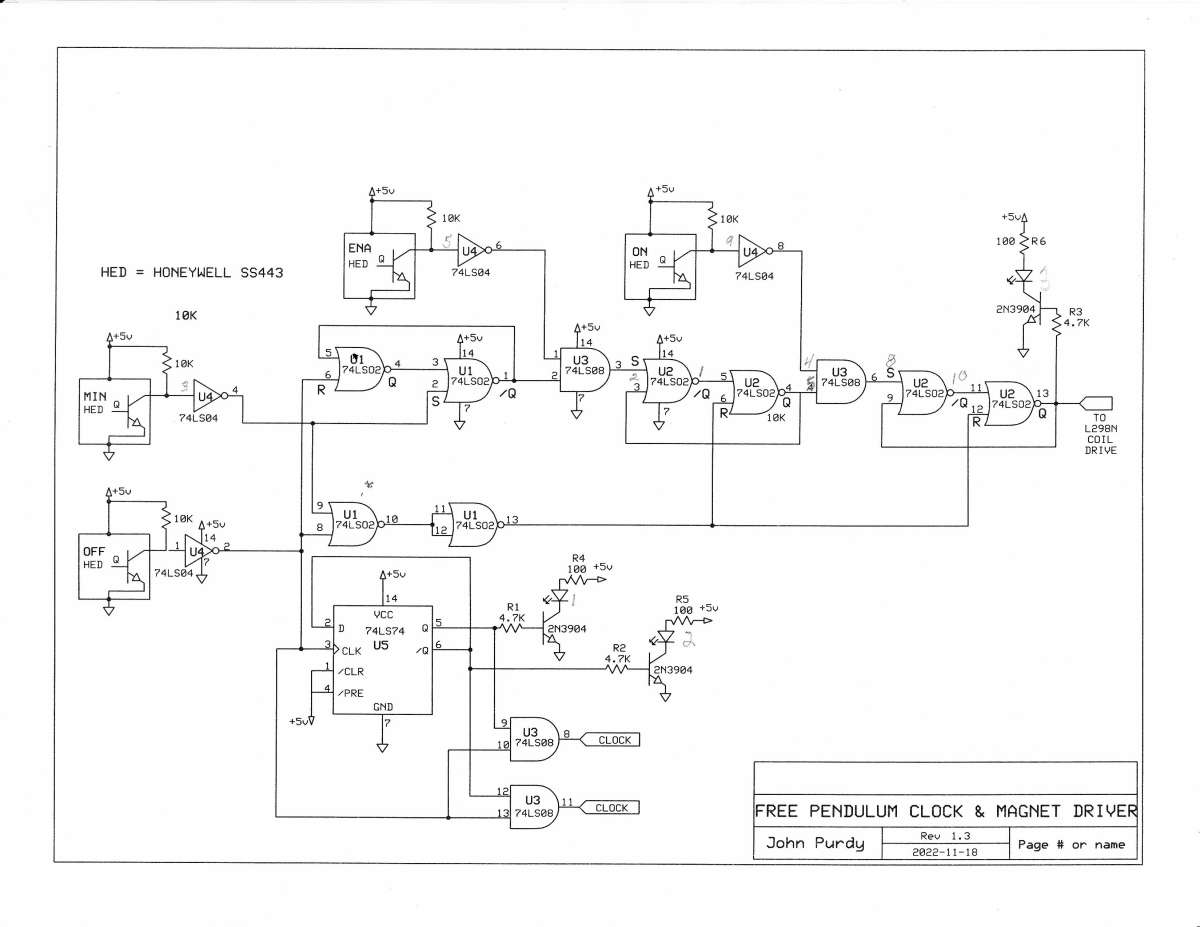
                            From your original post it looks like you are making a clock similar to the one I made. I used the drive circuit that you published in ME with some modifications of my own. I used 4 hall effect sensors for the pendulum and a iron bar on the bottom of the pendulum vice a magnet. I used two coils and the amp-turns of each was calculated as 775 by the program I used for the coil design. If you would like the Excel coil design program PM me your e-mail address and I will send it to you.

                            My clock has been running now for over 4 years and keeps reasonable time, considering it is in my unheated workshop and the pendulum rod is just stainless steel. I have a carbon fiber rod to replace it with but have never got around to it, one of these days. The output of the drive circuit send a one second pulse to a cheap battery clock unit with the internal drive circuit disconnected and my clock drive actuating the Laval stepper directly.

                            Johnclockdrive

                            CoilData

                            Scemo1.3

                            #865322
                            duncan webster 1
                            Participant
                              @duncanwebster1

                              I can only speak from experience. My first clock has 2 optos, and has been running for 20 or so years. It was last put right in early July when the power went off,  it is currently 2 minutes slow. I could readily make it run on one opto, but that would entail including a timing function generated by the processor, which is against my self imposed rules.

                              Using lots of logic gates instead of a processor is making life difficult, but each to his own.

                              To revert to theory, according to The Science of Clocks and Watches, the best time to impulse a pendulum is at mid travel, although I don’t think it really matters as long as you do exactly the same on every swing.

                              #865326
                              John Purdy
                              Participant
                                @johnpurdy78347

                                Duncan

                                The only reason I used discrete gates is because I had them and it was before I started playing with Arduinos and their ilk, besides, I like playing with logic circuits!

                                In mine the impulse is given to the pendulum right at mid stroke with the coils offset slightly so that it is just before the bar on the bottom of the pendulum reaches the poles of the coils. The 5 volt pulse to the coils is a square wave 94ms long and currently it occurs about every 14 seconds.

                                Just to correct an error in my previous, It should be a “Lavet” stepper not Laval.

                                John

                                #865329
                                carlw
                                Participant
                                  @carlw

                                  Duncan: I’ll second John’s use of gates rather than processor.  I learned relay ladder logic in 1964 and built my electro-Hipp drive circuit in DIP relays before converting to s-r flip-flops.  That is as far as I have gotten in electronics.  My poor tired old brain does not seem to work well with processor logic, so I am not going to go there.  I am curious about your 2 opto drive.  Can you supply some more details?

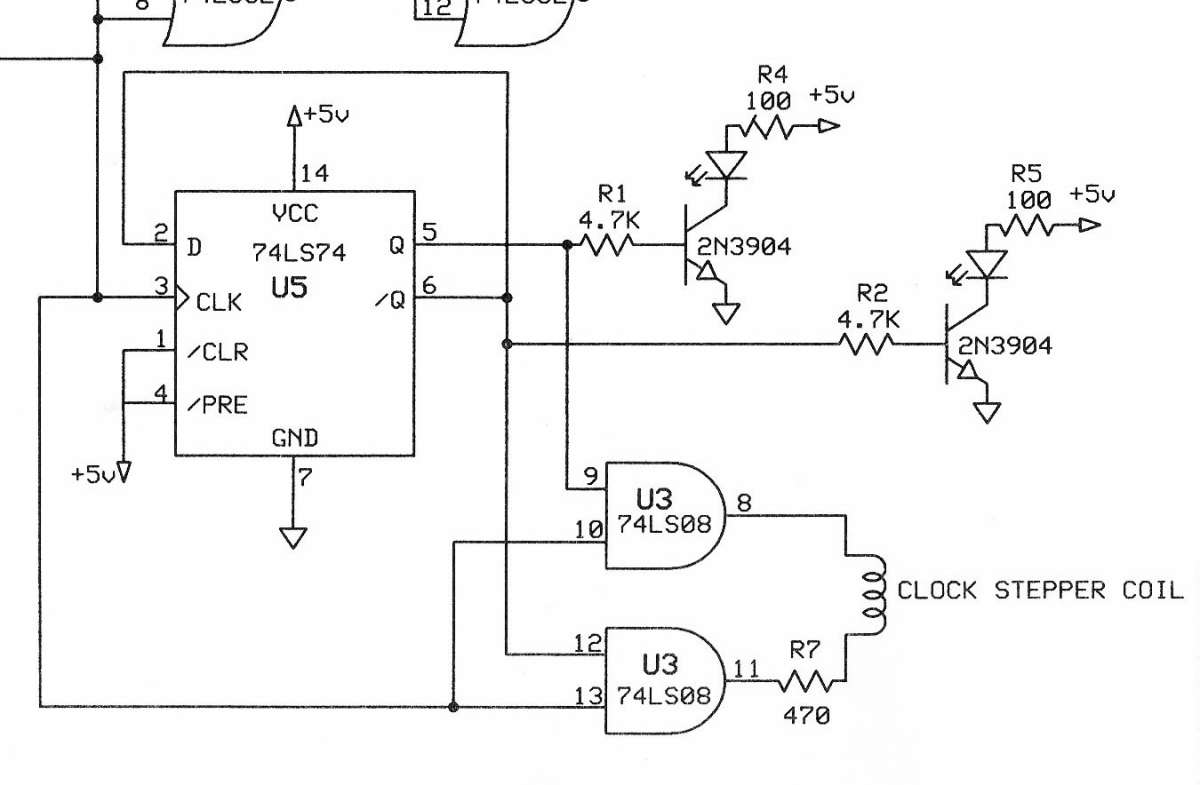
                                  John: I see the changes in my circuit and should be able to figure out your logic.  But I am lost on the D type flip-flop driving your slave clocks.  I would appreciate some explanation because I am thinking of driving the time-keeping unit via a stepper motor.  This is analogous to a slave clock.

                                  Yes, I am building a pendulum like yours.  Why does it have 2 coils and a bar pole piece?  I was planning to use one coil and a round NIB magnet in the end of the pendulum.  Your coils are much longer than I expected.  I have a bar of Delrin in the lathe and will wait for further info before I begin machining.  Thanks for the offer of the spreadsheet.  I have my own similar one.

                                  #865332
                                  carlw
                                  Participant
                                    @carlw

                                    John Haine: I almost missed your message.  I read the discussion in yur linkeabout sensing and drive coils.  There is a lot of ways of doing this, but I have decided to use the opto circuit similar to John Purdy’s.

                                    I assumed that vibration in the pendulum rod would a problem.  I did not know that the Synchronome pendulum vibrated and did not cause a problem.  Not many of them here in the States and I have only seen one.

                                    #865335
                                    John Purdy
                                    Participant
                                      @johnpurdy78347

                                      Carl

                                      I’m sorry, I have forgotten why I used two coils and a bar on the pendulum. I think it may have had something to do with not imparting a sideways motion to the pendulum, (or maybe not).

                                      As for the D flip-flop, I’m using one of the small quartz clock movements that are powered by a single AA battery for the clock. These use a “Lavet” type stepper motor that increment the second hand on each pulse applied to it. But being a single phase stepper successive pulses have to be of opposite polarity,hence the use of the D flip-flop where the Q and not Q outputs alternate states on each one second input pulse to the flip-flop’s clock input. The Q outputs are buffered by the 08 AND gate which are connected to the coil in the clock movement after the internal electronics are disconnected. The 470 ohm resistor is for current limiting as the output of the 08 is ~5 volts and the clock is designed to run on 1.5 volt. Hope this revised schematic makes it a little clearer.

                                      There is a good explanation of the workings of a Lavet stepper in MEW issue.

                                      You mention pendulums vibrating. When I first had mine running I had the coils too close to the bar on the pendulum, resulting in the pull on the bar when the coils were activated being so strong that the whole pendulum rod vibrated creating a load “twang” that could be heard clear across the shop!

                                      John


                                      FLIP-FLOP

                                      #865340
                                      John Purdy
                                      Participant
                                        @johnpurdy78347

                                        Carl

                                        That should have been MEW issue 318 for the explanation of the Lavet stepper!

                                        John

                                        #865349
                                        duncan webster 1
                                        Participant
                                          @duncanwebster1

                                          I have a narrow vane attached to the pendulum rod, with one opto arranged to be obscured at centre of swing, and a second opto at max travel. As the centre opto beam is broken the processor delivers a timed pulse to the horseshoe electromagnet, which attracts a bar on the end of the pendulum. If the swing gets too big, the offset opto is obstructed and the processor misses out the next pulse. Thus normally the pendulum is impulsed just before centre on every swing, with one missed out every now and again. The Fedchenko clock, possibly the most accurate pendulum clock ever made, impulsed by repulsion just after centre, so I have a fairly good precedent. For further details you’ll have to wait for an upcoming MEW article.


                                          #865366
                                          Joseph Noci 1
                                          Participant
                                            @josephnoci1
                                            On duncan webster 1 Said:

                                            I have a narrow vane attached to the pendulum rod, with one opto arranged to be obscured at centre of swing, and a second opto at max travel. As the centre opto beam is broken the processor delivers a timed pulse to the horseshoe electromagnet, which attracts a bar on the end of the pendulum. If the swing gets too big, the offset opto is obstructed and the processor misses out the next pulse.

                                            How do you cater for pendulum tilt Duncan? – All clocks tilt, or the house does, the floor does, with the daily temp/sun cycle. In your case tilt will cause a change of amplitude setpoint, and so rate will suffer.

                                            #865396
                                            duncan webster 1
                                            Participant
                                              @duncanwebster1

                                              That sort of refinement is for cleverer people than me. As long as it’s good for a few minutes between changing the clocks I’m happy. If I were to get that enthusiastic I think I’d copy your curved DRO scale idea

                                              #865436
                                              John Haine
                                              Participant
                                                @johnhaine32865

                                                I thought some sums might be useful. Let’s suppose that the pendulum bob weighs 50 Newtons (~5 kg), pendulum length is 1 meter (seconds beating), and swing amplitude 1/30 radians (~2 degrees) (i.e. total arc is 4 degrees). It’s relatively easy to get a Q of 10,000 in a pendulum like this if it isn’t doing any work such as driving a count wheel or mechanical escapement.

                                                The definition of Q is 2 x pi x (average stored energy) / (energy lost per cycle). For a high Q the average energy is ~ equal to the maximum when the bob is at its highest point. For our pendulum the bob lift at this highest point is (1 – cos(1/30)). Since cos(x) ~= 1 – x^2/2 + … for small x, then the max lift is

                                                1 – (1 – 1/(30^2 x 2)) = 1/1800 m (~0.55 mm). The stored PE is then (50 N)/1800 = 1/36 joules. So the energy lost per cycle is:

                                                2 x pi x (1/36)/10,000 = 17.45E-6 joules (17.45 microjoules). Assuming one impulse per cycle, the power input required is ~8.5 microwatts.

                                                We need to deliver this energy by a short push on the bob, tangentially to its circular path, ideally near BDC. The total excursion of the bob is ~1/30 m, 33 mm, either side of BDC. Let’s suppose we apply a tangential force F over a 10 mm span – the energy imparted will be 0.01 m x F. Equating this to the energy required the force needed is 1.75E-3 N, about 0.18 grams-weight. Not a lot!

                                                The scheme shown above applies a mainly vertical force downwards just before BDC. Because the pendulum isn’t quite vertical, there is a horizontal component of the force which can impulse the bob. Assume that the force is applied when the deflection is 1/60 radians (half amplitude).  The horizontal component is F(vert) x sin(1/60) ~= F(vert)/60.  Therefore we need to apply a vertical force to the pendulum bob 60 times greater than actually needed with this type of scheme. Not surprising that it may “twang”.

                                                So in my view whilst this type of arrangement is easy to set up it is far from ideal. For example, it can only impulse the pendulum either early or late, not in the centre of the swing. It is not how Fedchenko arranged his impulsing – more of that when I find some pictures.


                                                #865443
                                                John Haine
                                                Participant
                                                  @johnhaine32865

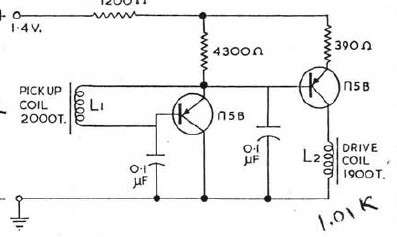
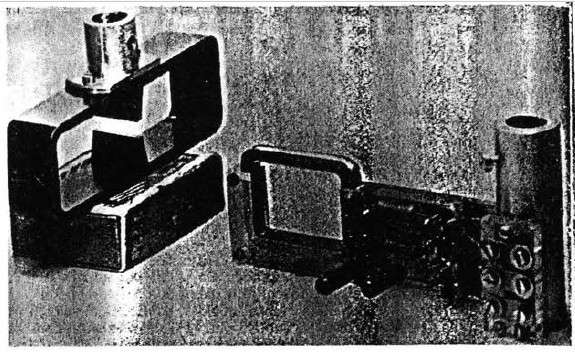
                                                  Here are a couple of pictures of the Fedchenko circuit and “motor”.

                                                  fedchenko_circuitfedchenko_drive

                                                  There is a rectangular former fixed to the clock with two windings on it. On the base of the rod is a steel “yoke” with two wedge-shaped magnets inside it which create a strong field between their points. The field maximum is arranged to coincide with BDC.

                                                  The yoke can be split to allow the coils to be threaded through, then reassembled. As the pendulum swings, as the coils pass through the field they generate a pulse which triggers the circuit.  Because the coils are tightly coupled the circuit regenerates so the transistors turn on for a short period, impulsing the pendulum very close to BDC. Because the coils and field are orthogonal the force is tangential to the motion as required. The coils generate opposite polarity on alternate swings, only one can trigger the circuit. As the pendulum Q is very high (~1 million, swinging in vacuum), only a tiny force is needed and the current pulses are very small. There is no amplitude control loop, but the suspension provides circular error compensation over a small range of amplitude. Circuit is run from a 1.4V mercury cell which has very constant voltage.

                                                  #865452
                                                  Michael Gilligan
                                                  Participant
                                                    @michaelgilligan61133

                                                    A very useful reference, John

                                                    Thanks

                                                    MichaelG.


                                                    #865461
                                                    Michael Gilligan
                                                    Participant
                                                      @michaelgilligan61133

                                                      As Mercury cells are widely banned … This may be of interest to Fedchenko enthusiasts 🙂

                                                      .

                                                      IMG_2060

                                                      .

                                                      MichaelG.


                                                    Viewing 25 posts - 1 through 25 (of 41 total)
                                                    • Please log in to reply to this topic. Registering is free and easy using the links on the menu at the top of this page.

                                                    Latest Replies

                                                    Viewing 25 topics - 1 through 25 (of 25 total)
                                                    Viewing 25 topics - 1 through 25 (of 25 total)

                                                    View full reply list.